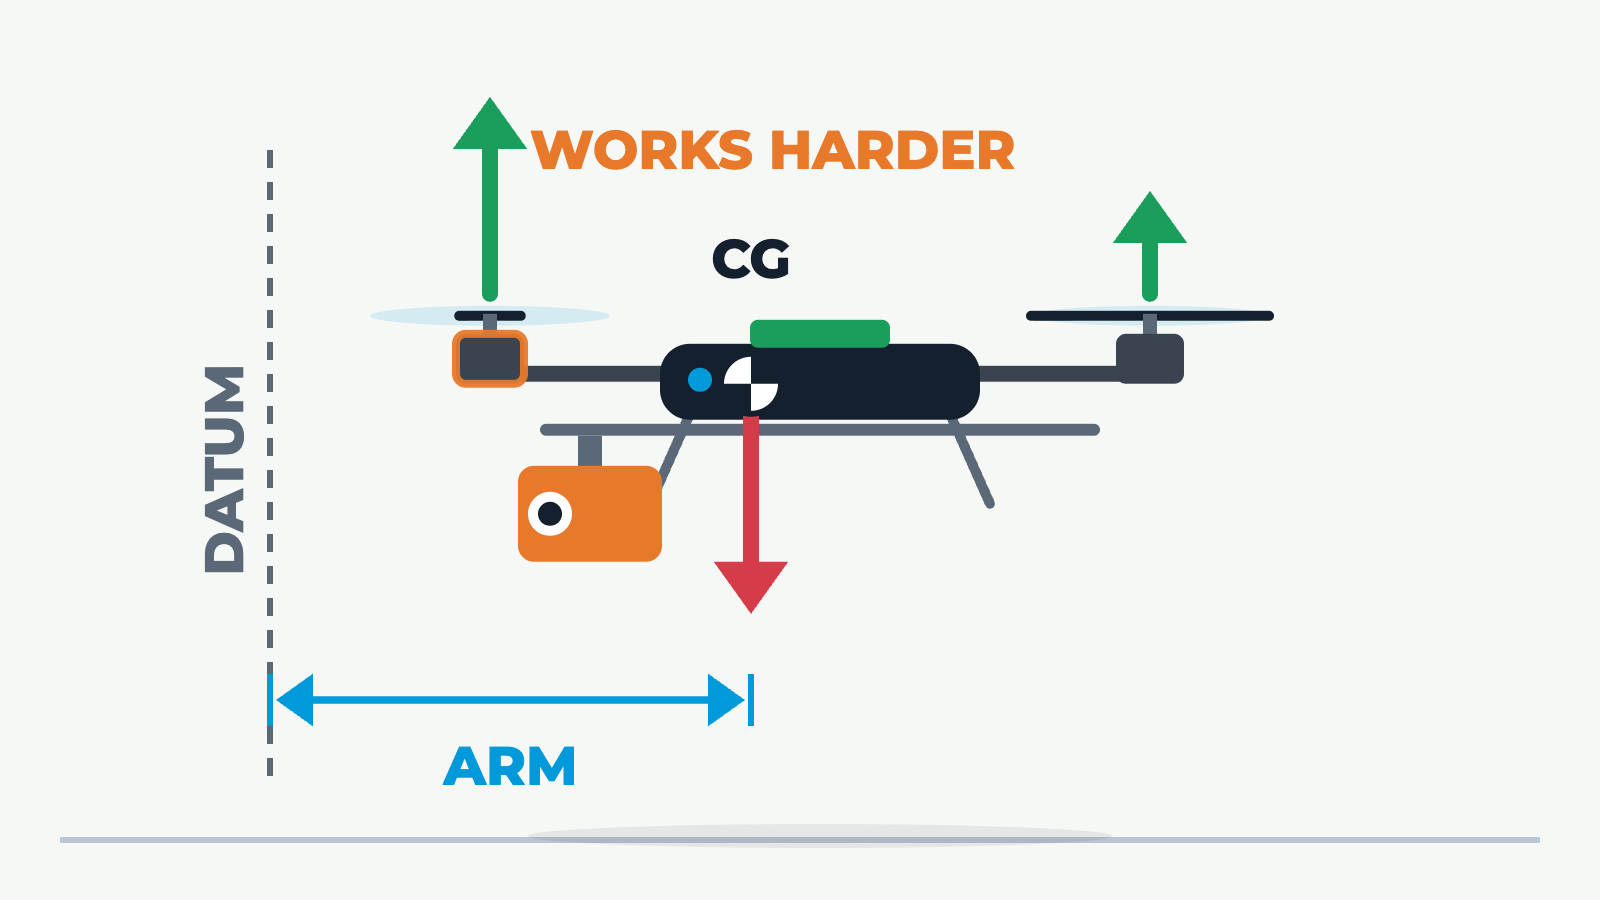
A 12 second loop showing a multirotor hovering, seen from the side with its nose to the left. A dashed datum line stands at the nose, and an arm dimension runs from the datum to the centre of gravity (CG). A payload hangs under the body. When the payload is centred, the CG is at the centre of the rotors and the front and rear thrust arrows are equal. When the payload slides forward, the CG moves forward, the arm gets shorter, the nose briefly dips, and the front motor, the one nearest the CG, makes more thrust and is marked as working harder while the rear motor makes less. When the payload slides aft, the rear motor works harder. The payload then returns to the centre. Thrust arrow lengths are schematic. The still frame shows the payload forward with the front motor working harder.