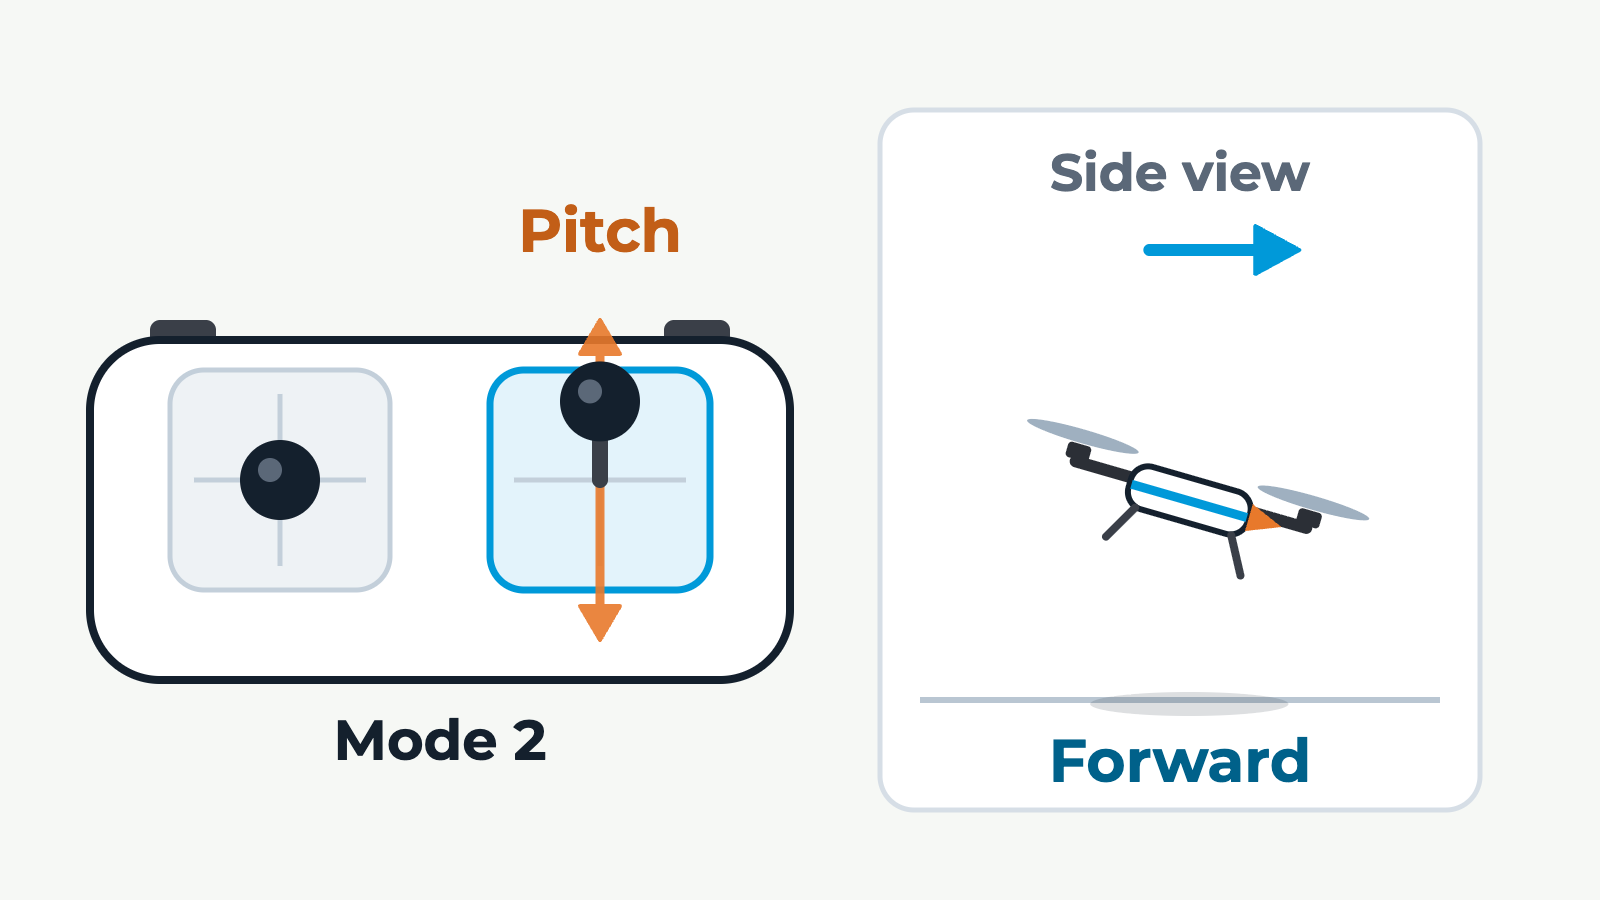
A simplified two-stick drone transmitter in Mode 2 beside a schematic multirotor. One input at a time: the left stick pushed up raises throttle and the drone climbs, pulled down it descends. The left stick pushed right yaws the nose right, seen from above, and pushed left yaws it left; the drone stays in place. The right stick pushed forward pitches the nose down and the drone flies forward; pulled back it flies backward. The right stick pushed right rolls the drone right and it moves right, seen from behind; pushed left it moves left. Each time the stick returns to centre the drone stops and holds, as in GPS mode. In Mode 1 throttle moves to the right stick and pitch to the left stick.